
Overview
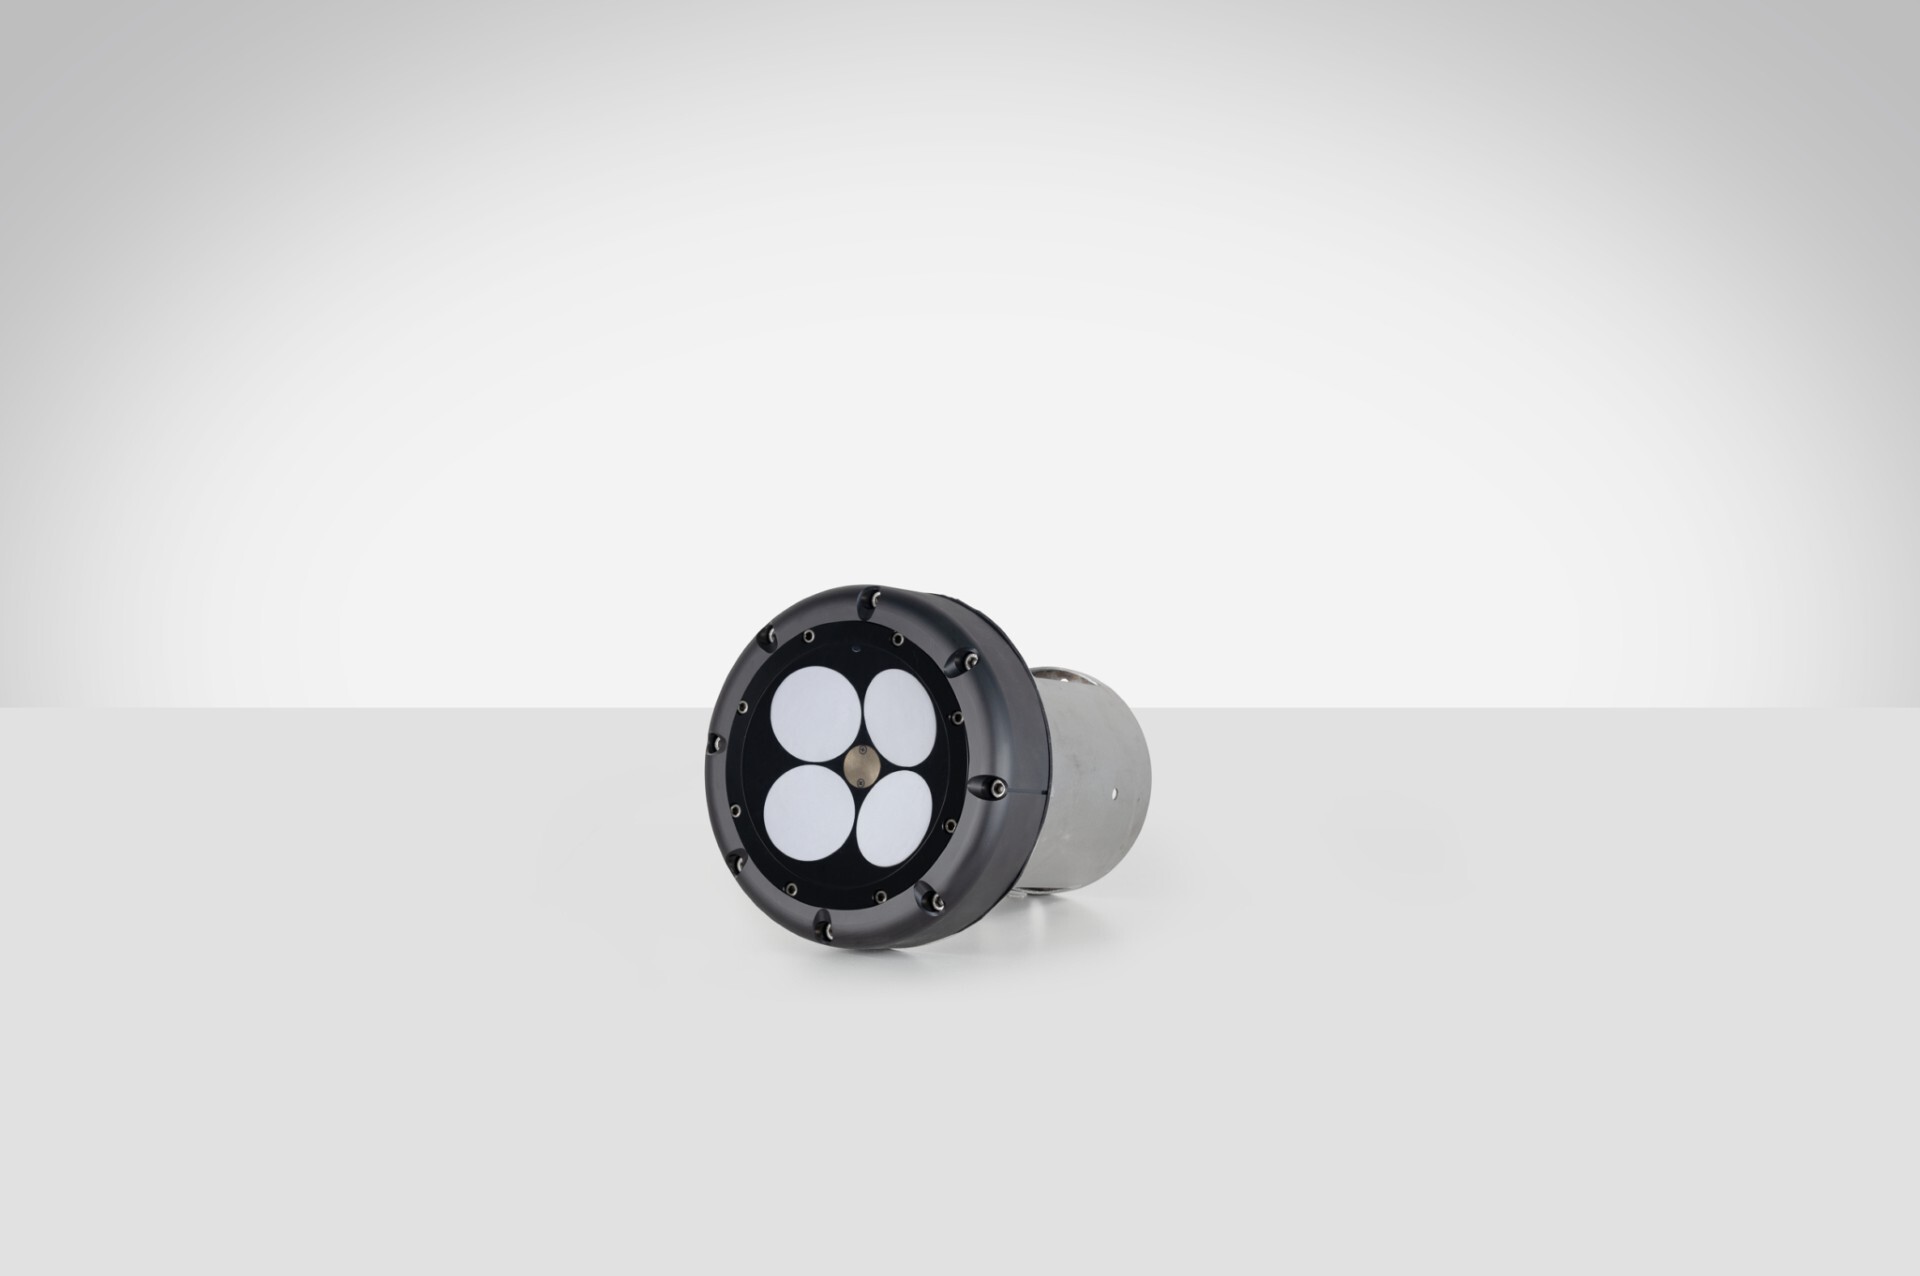
The DVL 333 Surface is a Doppler Velocity Log designed specifically for surface vessels. Traditional DVLs have a more vulnerable protruding head. The DVL 333 Surface mounts flush to the vehicle hull, alleviating this concern and minimizing drag and the risk of cavitation at the head.
When GNSS is lost, interfered with, or unavailable, relying on other navigational aids is key for uncrewed surface vessels (USVs) to complete missions. Combining a DVL with an INS constrains drift associated with INS-only navigation and ensures vehicle position or navigation in GNSS-denied environments. The DVL 333 Surface has been tested and proven in the challenging conditions of the Oslofjord to have impressive range and reliability.
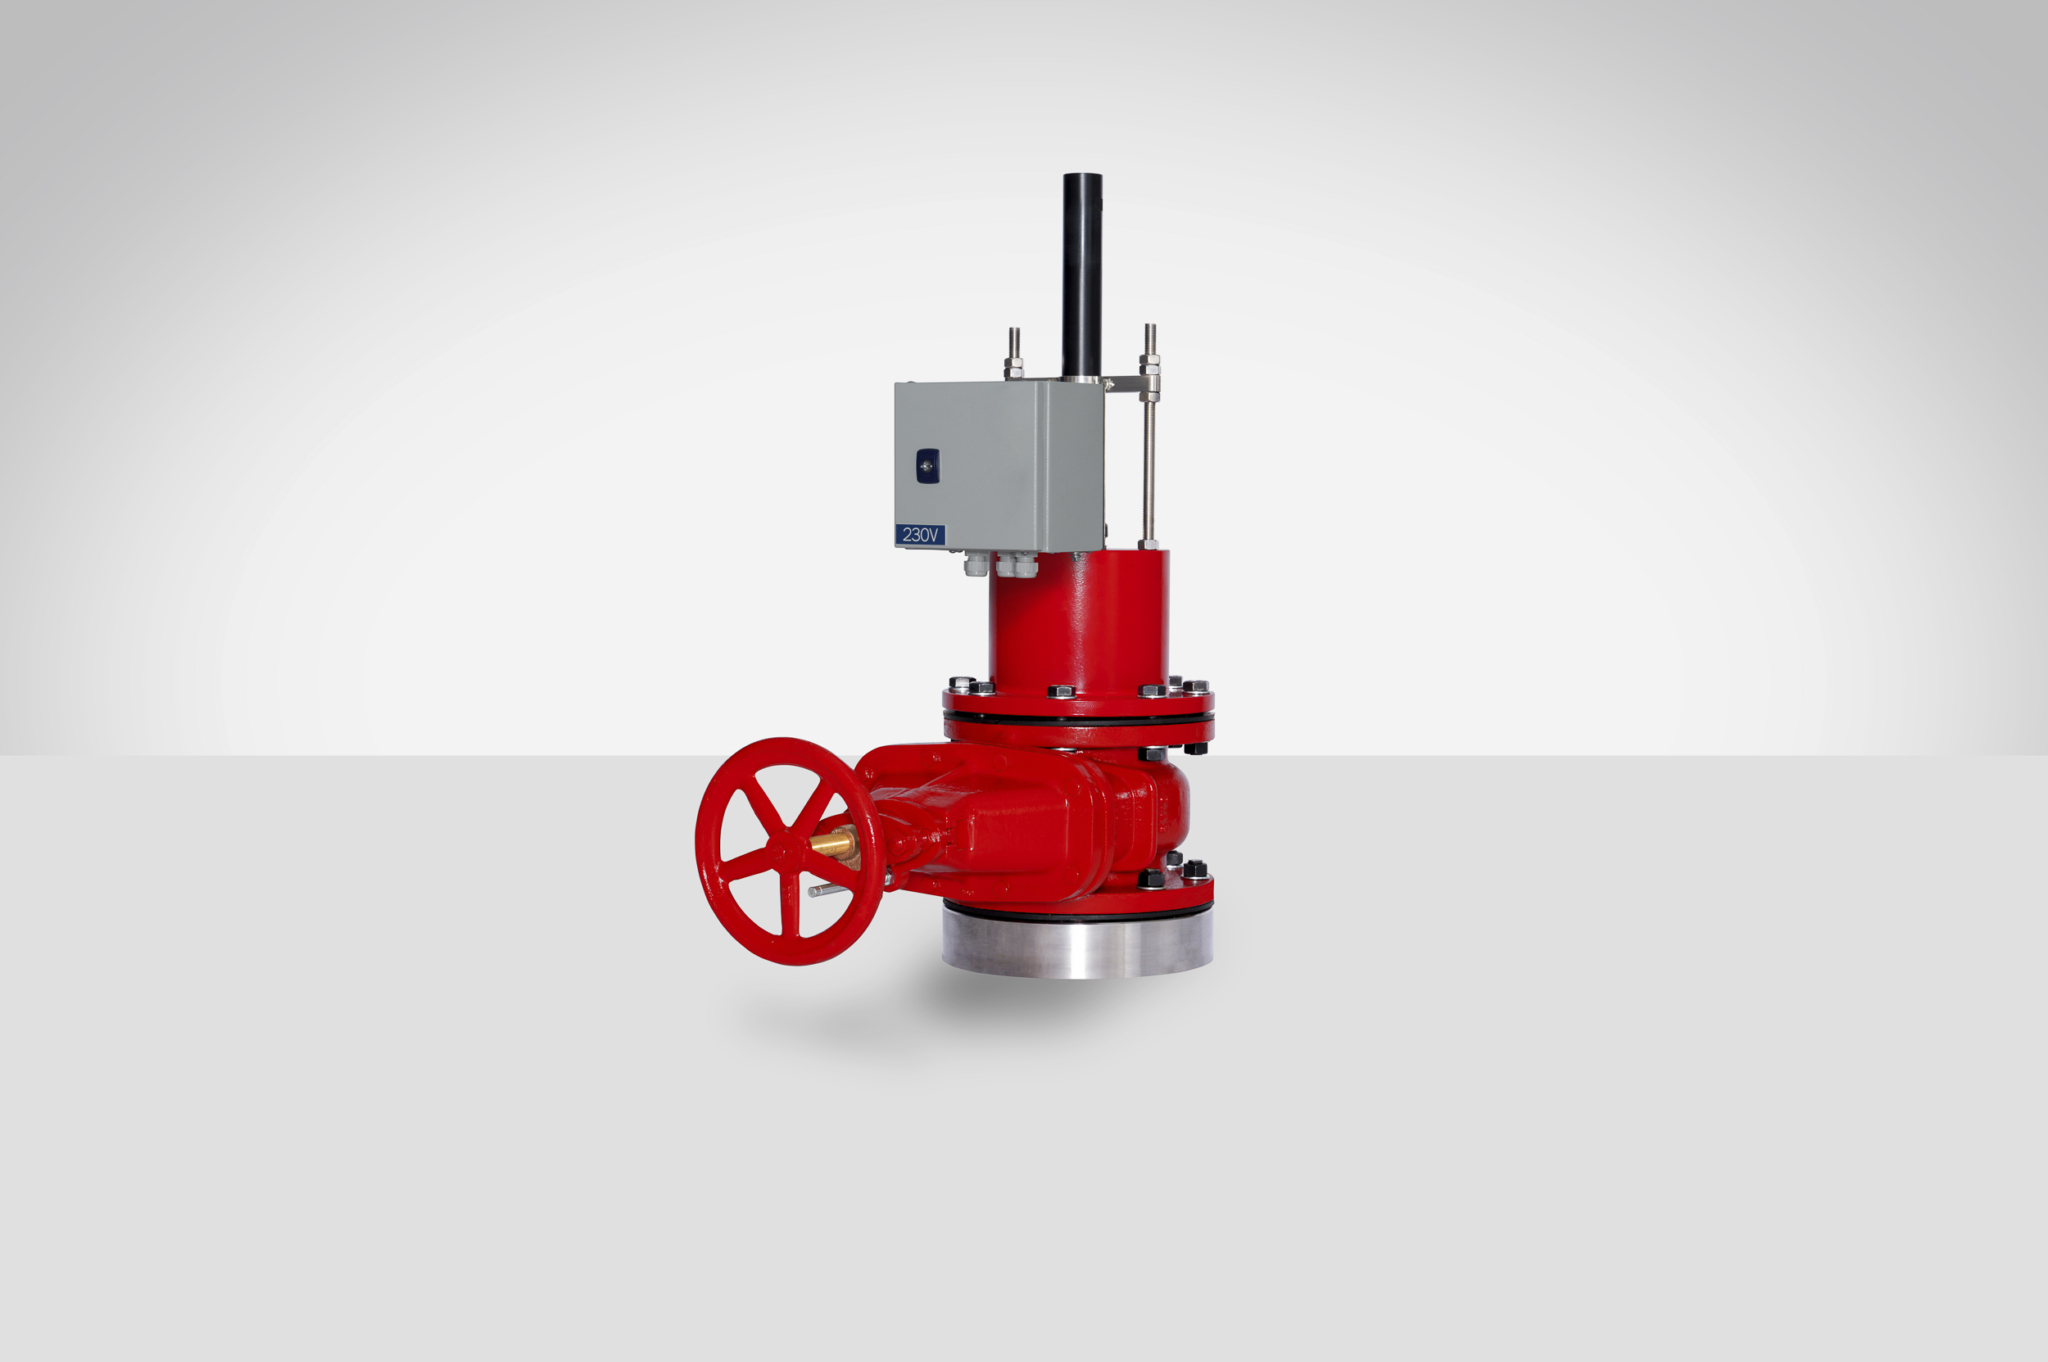
DVL 333 Surface is available with multiple mounting options.
Download our guide to Nortek DVLs here.
Looking for a complete system requiring INS aiding, current profiling and display capability? The DVL333 Surface can be upgraded to a full VM Operations system, adding current profiling, a processing unit, and VM Acquisition software.
- Currents
- Bottom track
Highlights
-
Maintain position or navigate when GNSS is lost
-
Ready for integration with leading INS
-
Flush-mounting form factor mitigates traditional challenges with surface vehicle navigation
Usage
-
USVs and crewed surface vessels requiring redundant navigation input
-
Vehicles requiring flush-mounting form factor
Integration
The DVL 333 Surface is designed for surface vessels. Flush-hull mounting minimizes errors associated with protruding transducer heads of traditional DVLs, enabling it to perform as an aid to navigation on fast-moving surface vessels.
Reliability
Tested in demanding conditions in the Oslo fjord, the DVL 333 Surface has a proven track record in areas of variable bathymetry and conditions. The water track feature provides a velocity backup if the bottom becomes out of range.
Results
The DVL 333 Surface, when combined with an INS, provides a reliable navigation aid for USVs when GNSS is lost. The addition of the DVL limits drift associated with INS-only navigation, maintaining vehicle position or enabling autonomous navigation in GNSS-denied environments.
Single ping std @ 1.5 m/s |
0.8 cm/s at 1/2 max altitude |
Long-term accuracy (1) |
±0.3% / ±0.1 cm/s (export-controlled), >1% (license-free) |
Minimum altitude |
0.25 m |
Maximum altitude |
|
Velocity resolution |
Better than 0.01 mm/s |
Maximum ping rate (3) |
8 Hz |
(1) Following standard calibration procedures |
|
(2) Bottom-track distance dependent upon bottom type |
Minimum accuracy |
0.3% of measured value ± 0.3 cm/s |
Minimum range |
4.0 m |
Minimum accuracy |
0.3% of measured value ± 0.3 cm/s |
Velocity resolution |
0.1 cm/s |
Interval |
Maximum sampling rate 2 Hz |
Maximum range* |
100 m |
Blanking |
0.5 m |
Cell size |
1-6 m |
Max # cells |
128 |
*Dependent on measurement conditions |
Operating temperature |
-4 to +40 °C |
Storage temperature |
-20 to +60 °C |
Vibration |
IEC60068-2-64 |
EMC approval |
IEC/EN 61000-6-2, 61000-6-3 |
Instrument materials |
POM with titanium fastener |
Weight |
7 kg |
Diameter |
196 mm |
Installation |
Sea valve, hull mount and pole mounted solution available |
Sea valve (option) |
DNV type approval; TAS00002CU |
Sea valve weight |
85 kg |
Bell housing material |
Steel DIN17121 |
Bell housing weight |
29 kg |
Frequency of operation |
333 kHz |
Beam width |
4.3° |
Configuration |
4-beam Janus array concave transducer, 25° beam angle |
Internal memory |
16 GB / 64 GB optional |
Bandwidth |
25% centered at transmit frequency |
Communication type |
Ethernet with auxiliary serial output using Subcon 8-pin male connector. |
Ethernet |
10/100 Mbits Auto MDI-X. TCP/IP, UDP/IP, HTTP protocols. Fixed IP / DHCP client /Auto IP address assignment. UPnP and Nortek proprietary instrument discovery over Ethernet. IEEE1588/PTP and NTP for absolute time stamping. Multiple simultaneous data format transmission possible. |
Data formats |
Nortek proprietary w/ 1 ms time stamp accuracy, NMEA0183. PD0, PD4, PD5, PD6 |
Trigger |
Internal 1, 2, 3, 4, 5, 6, 7 or 8 Hz or Trigger In. Trigger option through command (Ethernet) External TTL: (configurable Rising/Falling/Edges) |
Sensor |
0.1% FS /precision better than 0.002% of full scale per sample |
Temperature |
-4° to +40 °C ± 0.1 °C |
DC input |
12-48 V |
Maximum continuous current |
1.5 A |
Average power |
4.0 W (4) |
(4) Power based on 1 Hz sampling and altitude with greatest transmit pulse |
Standard models |
POM housing |
DVL 333 Surface
4 beam head
POM housing
64 GB
Compass and tilt
AHRS
Cable, 8 pin female ethernet AD2CP with TTL trigger
Bottom track
Current profiles, 4 beams. With upgrade to VM Operations.